Skip header

Rover

Basic functions

Rover K3P4

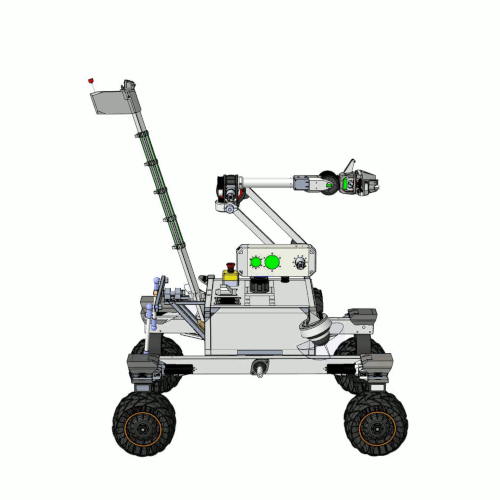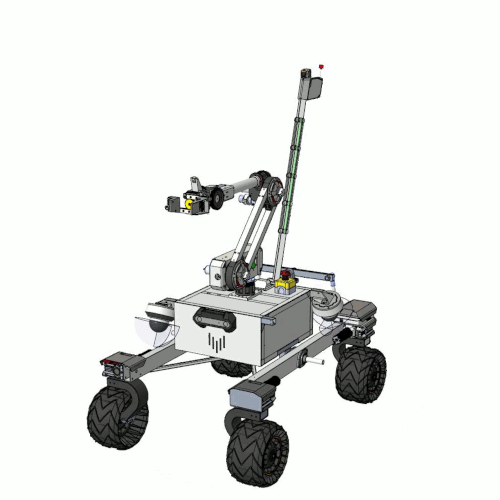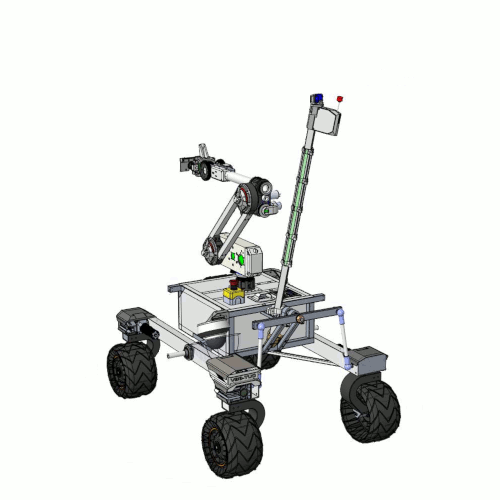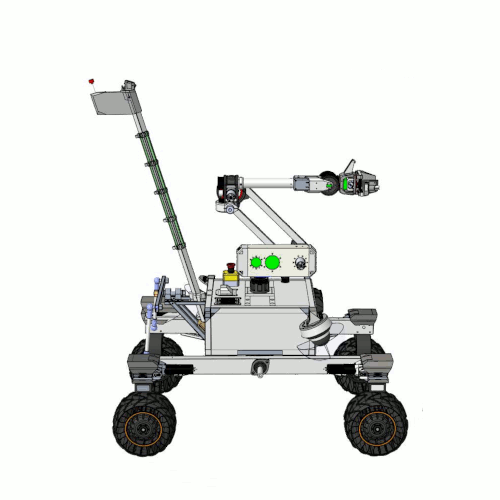
The K3P4 rover is designed to complete the tasks of rover competitions. We design, build and test it ourselves.

  • Versatile manipulator – six rotational degrees of freedom, lifting objects of various weights.
  • Interchangeable modules – different tasks require different tools; the rover's capabilities can be changed quickly with removable modules.
  • Sensors – a range of instruments for sensing the surroundings; two cameras give the operator an overview of the situation.
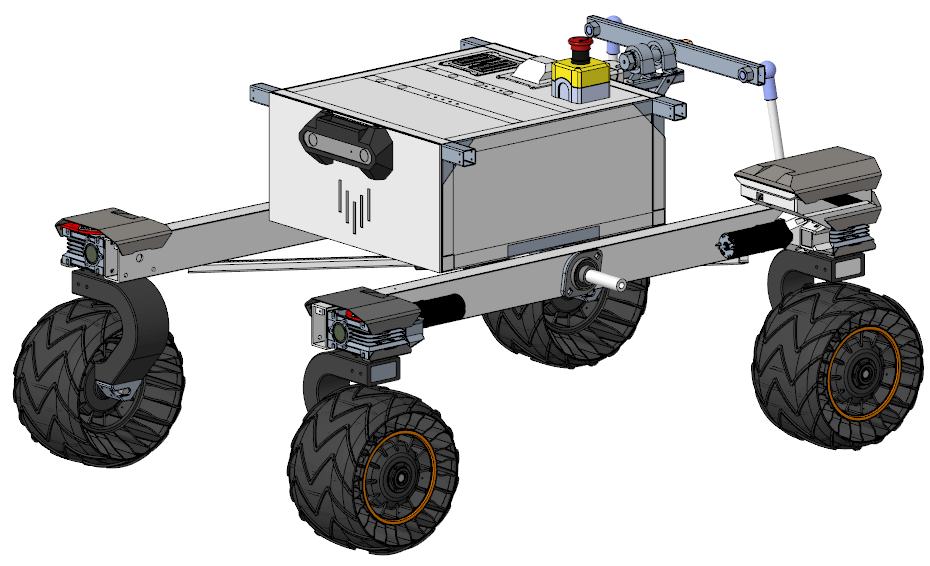
  • Chassis – a rocker suspension for tackling difficult terrain; each wheel steers independently, which is an advantage over skid steering.
Chassis

Rocker suspension of the rover

The rover has gone through several design changes, and it doesn't stop there – it keeps evolving with every new generation. We used a series of simulations to choose the suspension kinematics and suitable springs and dampers.

The frame carries all the important electronic components, and the other modules are mounted on it.

Terrain traversal

The wheels have integrated BLDC hub motors with planetary gearboxes. The rover can climb slopes of up to 45° and, thanks to its rocker suspension, overcome obstacles up to 300 mm high.

6DOF manipulator

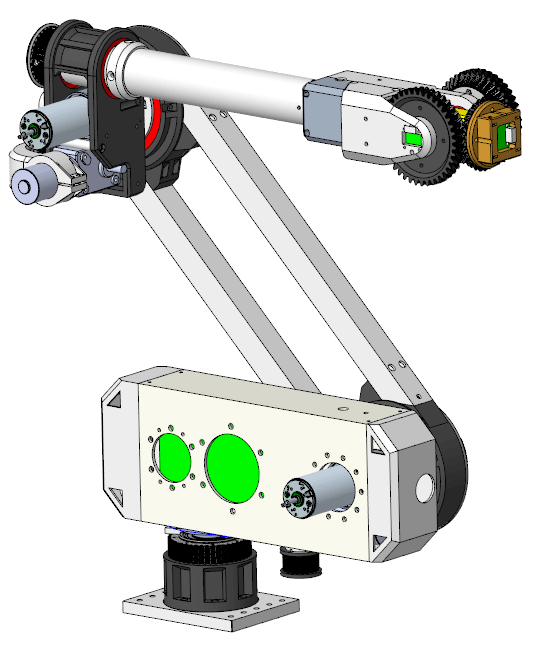
Manipulator with six degrees of freedom

Thanks to our own manipulator design, we can pick up objects from the ground on all sides of the rover.

All drives are electric DC motors with encoders, controlled by our own board and software located directly in the arm. This means the arm can also be tested on its own.

End effectors

End effectors

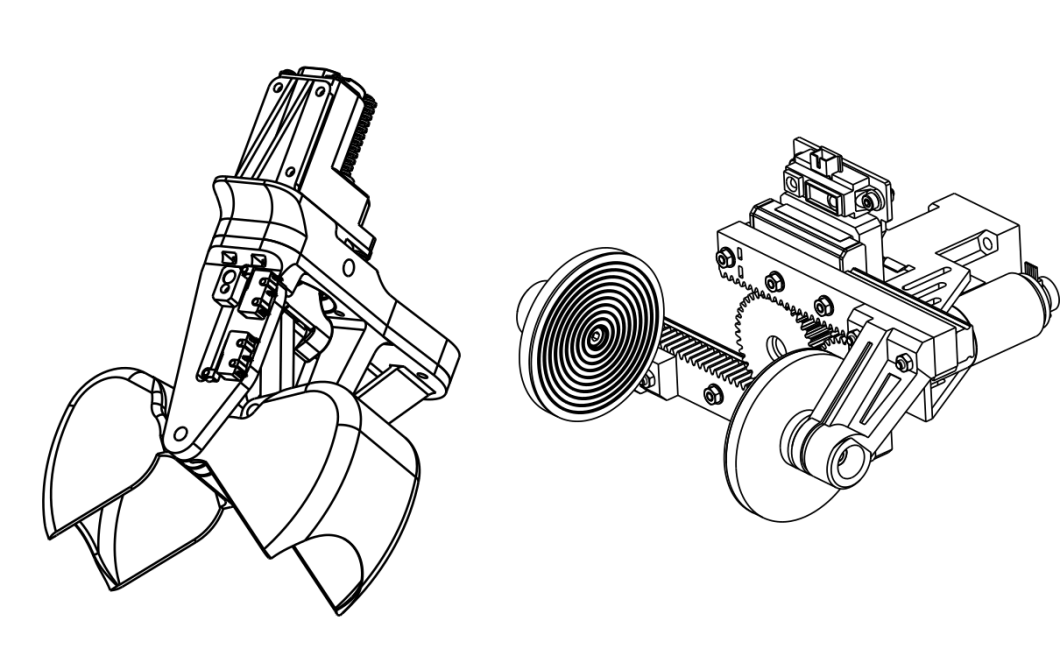
Different tasks require different tools, so we developed two end effectors: one for scooping and one for grasping.

The scooping end effector can take up to 200 g of soil from the surface and deliver it to the sample containers. The grasping end effector has a camera built into its jaws and can pick up various objects and operate industrial switches and knobs.

Wheels

The wheels are 3D printed from a flexible material. On rough surfaces they deform and keep traction.

Arm controller

We control the manipulator remotely with our own joystick and control board. It has three modes: direct teleoperation, autonomous mode and inverse kinematics mode.

Why K3P4?

It might sound like just a cool name for a robot, but it is an abbreviation of our department's internal code: Department of Robotics → Department 354 → Katedra tři pět čtyři → K3P4.